[September 2026] Four papers are accepted at CoRL 2026 : ROBO TTT (oral ), EgoScale (oral ), T-Rex , and SimFoundry .
[July 2026] Introducing ROBO TTT , scaling visuomotor context for robot policies and unlocks new capabilities, such as in-context imitation and on-the-fly improvement.
[June 2026] Releasing SimFoundry , automatically generating simulation environments from real-world videos for robot policy learning.
[June 2026] Introducing T-Rex , models and dataset for tactile-reactive dexterous manipulation.
[June 2026] Releasing StereoPolicy , adding geometric cues to robot policies via stereo perception.
[February 2026] Releasing EgoScale , a framework for scaling human video to unlock dexterous robot intelligence.
[January 2026] MoMaGen is accepted at ICLR 2026 .
[December 2025] Releasing GR00T N1.6 , an improved
open foundation model for generalist humanoid robots. Work done during part of my internship at NVIDIA
GEAR.
[December 2025] I'm delighted to receive
the NVIDIA
Graduate Fellowship . Thank you NVIDIA for the support!
[October 2025] Releasing MoMaGen , a new method to synthesize robot
demonstration data for mobile manipulation.
[September 2025] Introducing the 1st BEHAVIOR Challenge
at NeurIPS 2025.
[August 2025] BEHAVIOR Robot Suite (BRS) is
accepted at CoRL 2025 .
[April 2025] Organizing RSS 2025 Mobile Manipulation
workshop .
[March 2025] Introducing BEHAVIOR Robot Suite (BRS), a
comprehensive framework for learning whole-body manipulation in diverse household tasks.
[October 2024] Introducing Digital Cousins , which enable an
automated real-to-sim-to-real
pipeline for robust and scalable robot learning.
[September 2024] TRANSIC and Digital Cousins are accepted at CoRL 2024 .
[May 2024] Introducing TRANSIC , a holistic
human-in-the-loop method to tackle sim-to-real transfer for contact-rich robot manipulation.
[March 2024] Voyager is accepted at TMLR.
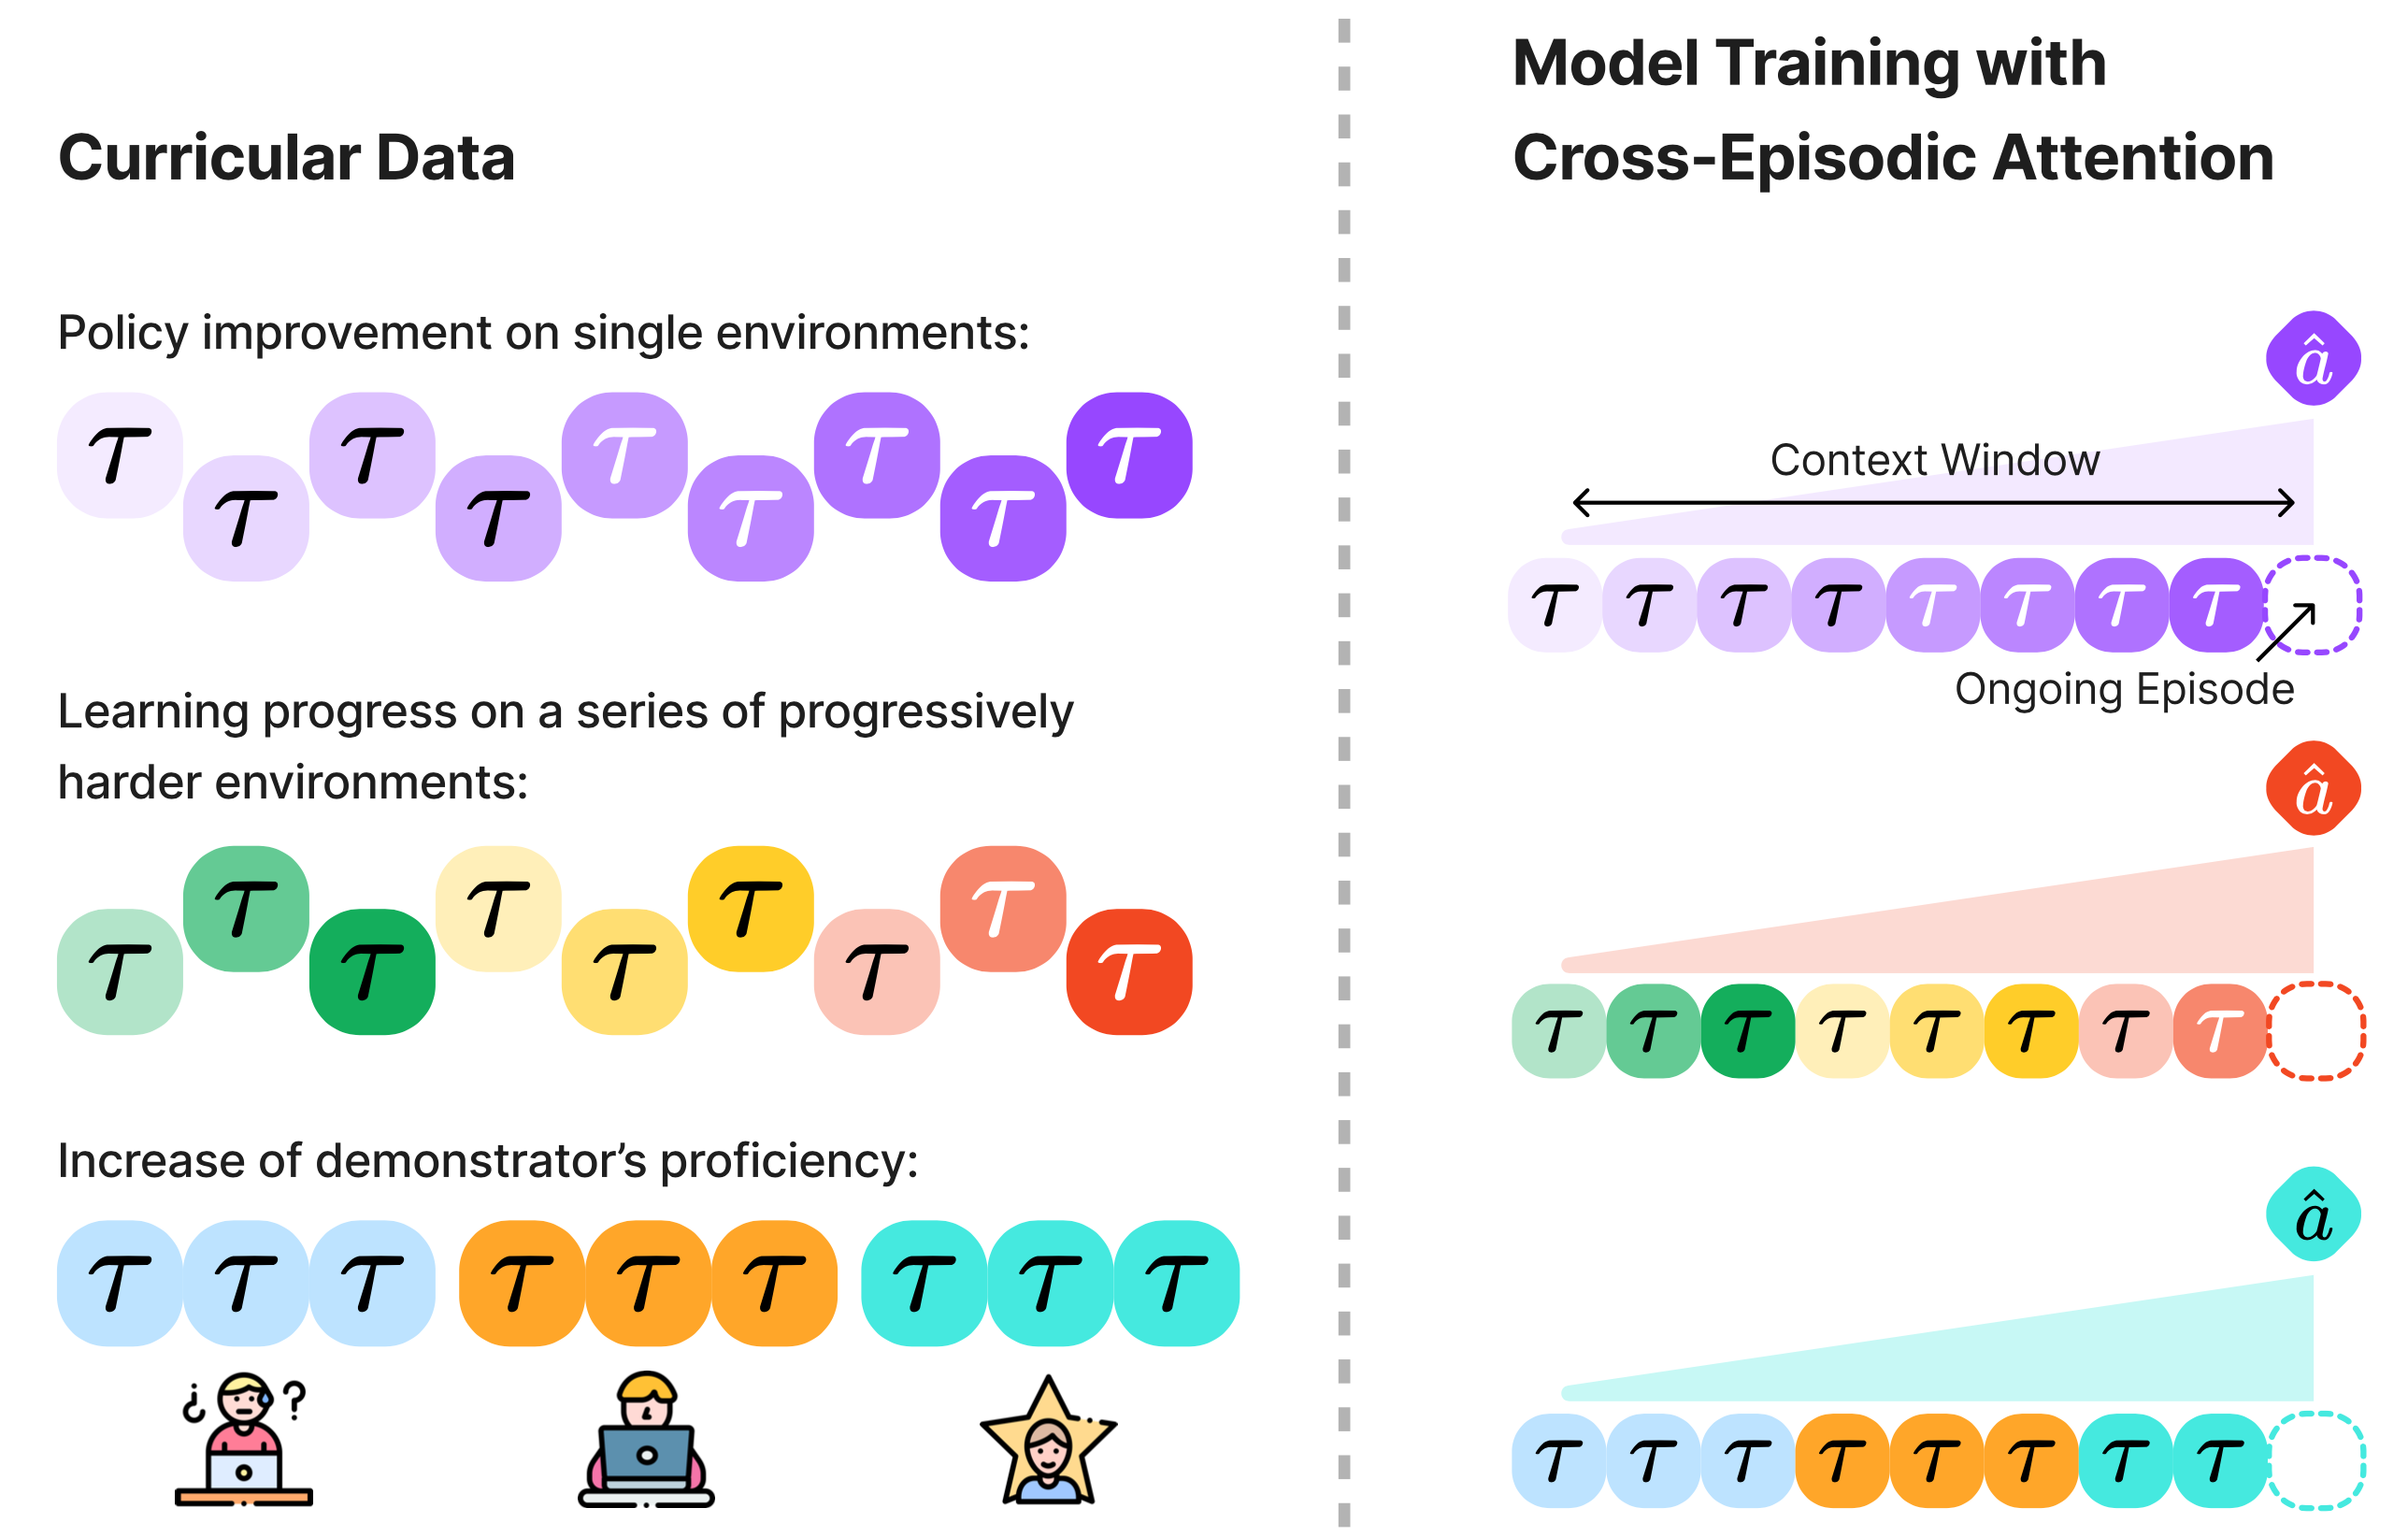
[September 2023] One paper called Cross-Episodic
Curriculum is accepted at NeurIPS 2023 . See you again in
NOLA.
[June 2023] I am glad to receive the prestigious Stanford School of Engineering Exceptional Master’s Student Award
[press] .
[June 2023] I will be interning at Boston Dynamics AI
Institute this summer.
[May 2023] We introduce Voyager , the first
LLM-powered embodied lifelong learning agent in an open-ended Minecraft world.
[April 2023] VIMA
is accepted at ICML 2023 . I'm also glad to
receive the conference travel grant. See y'all in Hawaii!
[April 2023] 📢 Life Update 📢 Decide to stay at Stanford for my PhD study!
[November 2022] I talk about VIMA in Foundation Models for
Decision Making workshop at NeurIPS 2022.
[November 2022] MineDojo
is accepted at NeurIPS 2022 D&B
track and wins the Outstanding Paper Award .
[October 2022] We design a Transformer agent, VIMA ,
that ingests multimodal prompts and solves a wide variety of robot manipulation tasks.
[June 2022] We release a new framework called MineDojo
for building generalist agents that can solve open-ended tasks with internet-scale knowledge in
Minecraft.
ROBO TTT: Context Scaling for Robot Policies
Yunfan Jiang ,
Yevgen Chebotar ,
Ruijie Zheng ,
Fengyuan Hu ,
Yunhao Ge ,
Jimmy Wu ,
Tianyuan Dai ,
Scott Reed ,
Li Fei-Fei † ,
Yuke Zhu † ,
Linxi "Jim" Fan †
CoRL 2026 Oral Presentation
arXiv | paper | website | tldr
Covered by State of AI Report 2026
T2-z: Test-Time Optimization of Environment Latents for Robotic World Models
Chenyuan Zhou * ,
Yining Hong * ,
Huang Huang ‡ ,
Yunfan Jiang ‡ ,
Wenlong Huang ‡ ,
David Held ,
Vitor Campagnolo Guizilini ,
Yue Wang ,
Li Fei-Fei ,
Jiajun Wu † ,
Leonidas Guibas † ,
Yejin Choi †
arXiv 2026
arXiv | paper | website | code | data
SimFoundry: Modular and Automated Scene Generation for Policy Learning and Evaluation
Nadun Ranawaka * ,
Josiah Wong * ,
Wei-Lin Pai ,
Wei-Teng Chu ,
Tianyuan Dai ,
Masoud Moghani ,
Hang Yin ,
Yunfan Jiang ,
Wesley Durbano ,
Brandon Huynh ,
Yu Fang ,
Linxi "Jim" Fan ,
Danfei Xu ,
Ruohan Zhang ,
Li Fei-Fei ,
Bowen Wen ,
Ajay Mandlekar † ,
Yuke Zhu †
CoRL 2026
arXiv | paper | website | tldr
Covered by State of AI Report 2026
T-Rex: Tactile-Reactive Dexterous Manipulation
Dantong Niu * ,
Zhuoyang Liu * ,
Zekai Wang * ,
Boning Shao ,
Zhao-Heng Yin ,
Anirudh Pai ,
Yuvan Sharma ,
Stefano Saravalle ,
Ruijie Zheng ,
Jing Wang ,
Ryan Punamiya ,
Mengda Xu ,
Yuqi Xie ,
Yunfan Jiang ,
Letian Fu ,
Konstantinos Kallidromitis ,
Matteo Gioia ,
Junyi Zhang ,
Jiaxin Ge ,
Haiwen Feng ,
Fabio Galasso ,
Wei Zhan ,
David M. Chan ,
Yutong Bai ,
Roei Herzig ,
Jiahui Lei ,
Li Fei-Fei ,
Ken Goldberg ,
Jitendra Malik ,
Pieter Abbeel ,
Yuke Zhu ,
Danfei Xu ,
Linxi "Jim" Fan ,
Trevor Darrell
CoRL 2026
arXiv | paper | website | code | model | data | tldr
EgoScale: Scaling Dexterous Manipulation with Diverse Egocentric Human Data
Ruijie Zheng * ,
Dantong Niu * ,
Yuqi Xie * ,
Jing Wang ,
Mengda Xu ,
Yunfan Jiang ,
Fernando Castañeda ,
Fengyuan Hu ,
You Liang Tan ,
Letian Fu ,
Trevor Darrell ,
Furong Huang ,
Yuke Zhu † ,
Danfei Xu † ,
Linxi "Jim" Fan †
CoRL 2026 Oral Presentation
arXiv | paper | website | tldr
GR00T N1.6: An Improved Open Foundation Model for Generalist Humanoid Robots
NVIDIA GEAR Team
blog |
code | model | data
MoMaGen: Generating Demonstrations under Soft and Hard Constraints for Multi-Step Bimanual
Mobile Manipulation
Chengshu Li * , Mengdi Xu * , Arpit Bahety * , Hang Yin * , Yunfan Jiang , Huang
Huang , Josiah Wong , Sujay Garlanka , Cem Gokmen , Ruohan Zhang , Weiyu
Liu , Jiajun
Wu , Roberto Martín-Martín , Li
Fei-Fei
ICLR 2026
arXiv | paper | website | code | doc | tldr
Open X-Embodiment: Robotic Learning Datasets and RT-X Models
Open X-Embodiment Collaboration
ICRA 2024
arXiv | paper | website | data | tldr
MineDojo: Building Open-Ended Embodied Agents with Internet-Scale Knowledge
Linxi "Jim" Fan , Guanzhi Wang * , Yunfan
Jiang * , Ajay Mandlekar ,
Yuncong Yang , Haoyi Zhu , Andrew Tang , De-An Huang , Yuke Zhu † , Anima Anandkumar †
NeurIPS 2022 Datasets and Benchmarks Track
🎉 Outstanding Paper Award 🎉
Featured Paper (Oral-Equivalent)
arXiv | paper | website | code | tldr
Covered by NVIDIA Blog , Two Minute Papers , and Ars Technica
© 2021 - 2026 Yunfan Jiang